|
VDL CropTeq Robotics
© VDL Groep 2026

Using our expertise and technology, we have developed an autonomous leaf-cutting robot for cucumber plants in high-wire cultivation. Thanks to smart crop adaptations and a minor optimisation of the AI algorithm, the robot can also be used in tomato cultivation. Autonomous harvesting and automation for other crops and flowers are part of our roadmap.
The patented end effector for leaf cutting is robust and tolerant of positioning variations, enabling reliable autonomous operation. The CropTeq platform also supports other applications, such as harvesting, precision spraying and insect detection. The system supports standard data collection, giving growers insight into growth, yield and future harvest forecasts.

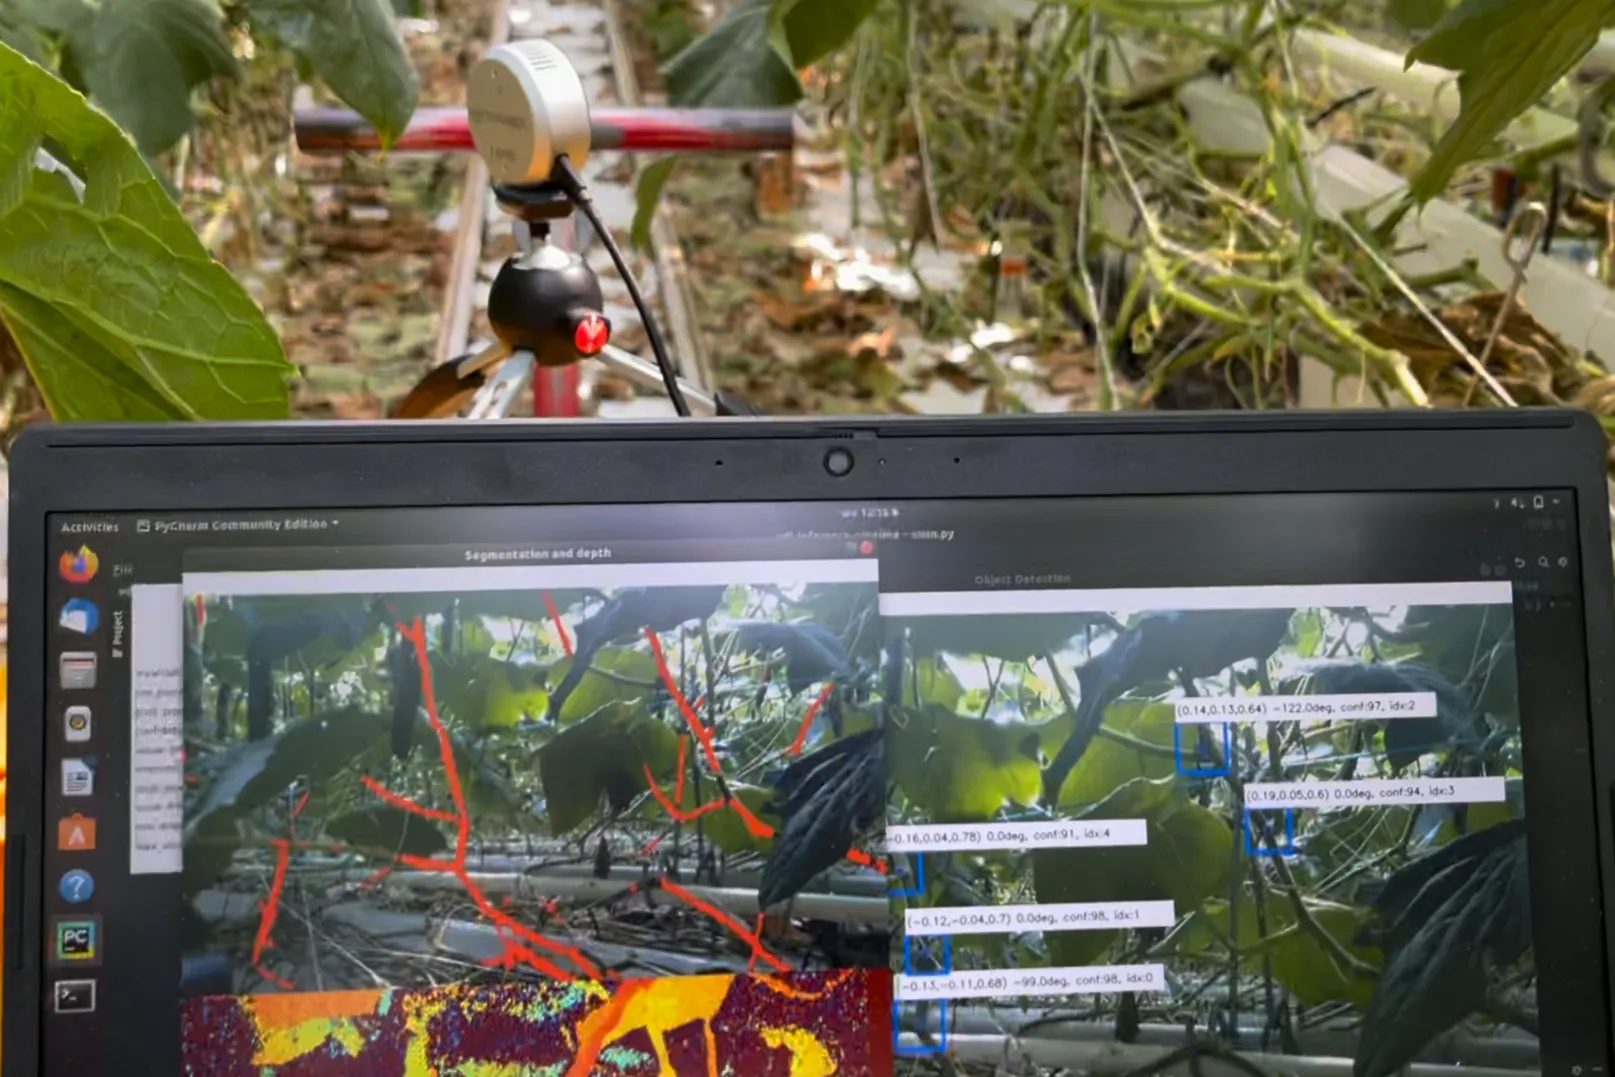
A robot that must autonomously prune leaves and therefore continually adapt needs AI. With a vision system, an intelligent neural network and a correctly selected camera, it is possible to recognise an object and its position. Using additional techniques and a plant model, we have developed a movement and end-effector strategy.
With enough images, you can train an algorithm so that the system recognises the right things. Training is a new word for programming. However, you do not have to be a software specialist to do this. Refining the algorithms and recognising the plant does require knowledge and insight. Once you have them, continually improving them is something the grower could also do.
Artificial intelligence therefore creates the recognition software itself, rather than a human. AI software is consequently never 100% reliable, so you cannot use it to prune or harvest fruit with 100% accuracy either. Perhaps 95%, for example, but that can decrease with different lighting conditions, etc.
Despite this limitation, it is AI that makes automation in the greenhouse possible.
A robot generates a lot of data. This is stored via our IoT platform in a Data Lake, where the data can be enriched if desired and shared with third parties via a secure connection. We distinguish three types of data: machine data, application data and training data.
We use machine data to monitor and analyse the system in order to continuously improve performance, for example in the area of energy management. Application data, such as temperature, light, humidity and CO₂, provides growers with valuable insights for optimising the cultivation process. This data is not measured as standard, but can easily be added. The raw data remains the grower’s property.
Training data consists of images that the vision system does not yet recognise with sufficient certainty. This is used for reinforcement learning, allowing all robots to learn from one another’s experiences and quickly adapt to changing circumstances.
Our robotic path planning also sets us apart. It is not merely about moving from A to B, but about adapting movements in real time and avoiding collisions at high speed. That is where the intelligence of our system lies.

A robotic arm moving from A to B is nothing new. An arm that must continuously adjust its movement and avoid collisions is the innovation. And all of that in real time at maximum speeds. That is where the intelligence of our system lies.
Ultimately, no one wants a robot to keep hitting the plant, so you move around it.

Accuracy is generally not an issue for a robot. In the greenhouse, however, the camera and vision system determine the inaccuracy. The robustness of the cutting system is therefore crucial. We have chosen a patented gripper that also causes as little stress to the plant as possible.
A robot can be very fast. On the one hand, safety requirements limit the movement speed of the cobot arms; on the other, handling the plant carefully also limits the speed. Ultimately, it is mainly the movement from leaf to leaf and the EOAT cycle time that are decisive. The vision system and image processing are not on the critical path of the motion planning. We guarantee an average of 1,000 leaves per hour over 100 m.
Economically viable, because the system’s variable costs are very low. The variable costs and depreciation of the investment result in an hourly robot rate that is substantially lower than labour costs. The system’s speed is essential in this respect, and will only increase. The software is the dominant factor, which means that a significant part of the variable costs consists of software maintenance and licence costs.